Described in words, never drawnPass
Indoor Delivery Rover
One paragraph of plain English became a spec, a twin, and a measured PASS. Its odometry matched ground truth to 0.002%.
Drive error
0.398%
Turn error
3.653°
Describe a robot or paste its parts list. Muse Spark drafts the spec, RobotForge catches the numbers that don't add up, and a simulated twin has to pass a measured motion test.
Spec drafting by Muse Spark via the Meta Model API · twin and gate in Gazebo Sim
Every robot goes through the same path. Nothing downstream trusts the step before it: the model's spec is checked, and the twin is measured.
Plain words, a pasted parts list, or a photo.
Muse Spark drafts a strict, structured hardware spec.
Engineering checks catch impossible or inconsistent numbers.
The twin drives 1 m and turns 90° in Gazebo, graded on ground truth.
URDF, a printable take-apart kit, and what's missing to buy.
Thresholds are locked: distance error 5% passes and over 10% fails, heading error 5° passes and over 10° fails. Here is one robot that earned a PASS, and one that was rigged to fail.
One paragraph of plain English became a spec, a twin, and a measured PASS. Its odometry matched ground truth to 0.002%.
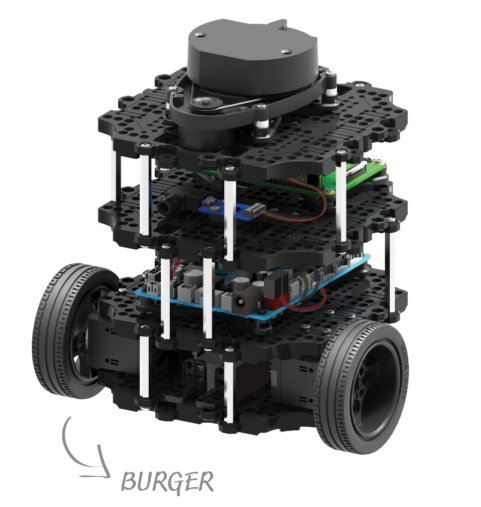
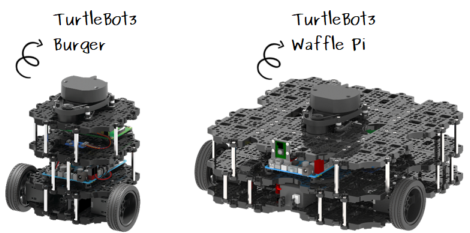
TurtleBot3 Burger with its physical wheels shrunk to 0.9× while odometry kept believing the spec. The robot's own sensors couldn't see it. The gate could.
Bars run 0–15. Green zone passes, yellow is marginal, past it fails. Recorded in Gazebo Sim, headless, Oct 26, 2026.
All gate reports →Each badge comes only from recorded gate runs. A robot that hasn't been gated says so in grey instead of borrowing a green it hasn't earned.




The model sits on the critical path, and nothing it says is trusted until it is checked and measured.
Through the Meta Model API in Standard mode. It turns words or a photo into a strict spec schema and never writes simulation code.
It locates parts in the picture independently. When it disagrees with Spark, both answers are printed, not smoothed over.
Drive and turn are judged against the simulator's true pose. Odometry is graded too, so a robot can't pass on its own word.
| Measurement | Pass | Marginal | Fail |
|---|---|---|---|
| Distance error | ≤ 5% | 5–10% | > 10% |
| Heading error | ≤ 5° | 5–10° | > 10° |
pip install -e .
robotforge describe "a four-wheel rover, 30 cm long, with a front ultrasonic sensor" --mock --out rover.json
robotforge validate rover.json
robotforge urdf rover.json --out build/rover.urdf
robotforge run-gate rover.jsonStep through a real recorded run: the paragraph, the spec Muse Spark returned, the checks, and the gate's measured verdict.
Open the app →