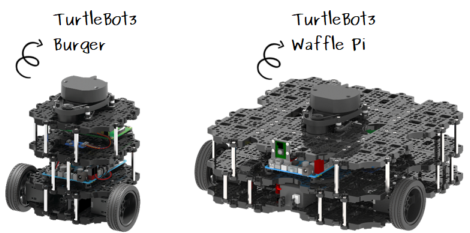
TurtleBot3 Waffle Pi
The bigger TurtleBot3: a waffle-shaped deck carrying a lidar and a camera. RobotForge knows this one from a photograph — the photo intake identified it and drafted its spec, so every dimension here is an estimate until somebody measures the real robot.
Spec
| Drivetrain | differential — 2 driven wheels + caster |
|---|---|
| Footprint | 0.306 m x 0.281 m x 0.141 m — ESTIMATED from the photo draft, based on the published approximate size |
| Mass | 1.8 kg (photo draft) |
| Motors | 2x Dynamixel XL430 (photo draft) |
| Sensors | 2D lidar (top), RGB camera (front), IMU, wheel encoders |
| Wheels | 66 mm diameter (photo draft) |
examples/photo-turtlebot.jsonThe spec is a photo draft (all dimensions ESTIMATED) produced by `robotforge describe --photo`; the official Waffle Pi URDF was pulled by `robotforge lookup` under Apache-2.0.Gate runs
Measured against simulator ground truth at the locked thresholds: pass ≤ 5% / 5°, fail over 10% / 10°. The gate tests the spec's simulated twin, not a physical robot.
No recorded gate runs yet. This robot has no verdict until one is measured.
Harness checks
Electrical computations over this robot's documented wiring graph — voltage drop, ampacity, logic levels, rail budgets, connector matching. Not a gate run and not a simulation: each check is Checked, Partial or Not checked, and the headline is counts, never a blanket pass.
3 checked clean · 0 with warnings · 0 with errors · 0 partial · 20 not checked · missing data: cable.gauge_awg ×8, connector at both ends (connector_from / connector_to) ×6, current_a for lidar ×5
| Check | Checked | Partial | Not checked |
|---|---|---|---|
| voltage drop | 0 | 0 | 4 |
| ampacity | 0 | 0 | 4 |
| logic levels | 1 | 0 | 3 |
| rail budget | 0 | 0 | 3 |
| connector match | 2 | 0 | 6 |
Findings: none — the inputs that could be checked raised nothing. That is not the same as everything being checked; the counts above say how much was.
Missing data — the datasheets still to hunt. A check that could not run says what it needs:
| Missing input | Blocks | Needed by |
|---|---|---|
cable.gauge_awg | 8 | battery -> driver, driver -> motors, battery -> controller, controller -> lidar |
connector at both ends (connector_from / connector_to) | 6 | battery -> driver, battery -> controller, controller -> lidar, controller -> camera … |
current_a for lidar | 5 | battery -> controller, controller -> lidar, controller rail |
current_a for motors | 5 | battery -> driver, driver -> motors, driver rail |
cable.length_mm | 4 | battery -> driver, driver -> motors, battery -> controller, controller -> lidar |
connection voltage (volts) | 2 | battery -> controller, controller -> lidar |
current_a for controller | 1 | battery rail |
current_a for driver | 1 | battery rail |
logic_v for camera | 1 | controller -> camera |
logic_v for imu | 1 | controller -> imu |
logic_v for lidar | 1 | controller -> lidar |
rated output current for battery | 1 | battery rail |
rated output current for controller | 1 | controller rail |
rated output current for driver | 1 | driver rail |
Report: catalog/harness-reports/turtlebot3-waffle-pi.json · checked 2026-10-27 · reproduce with robotforge harness examples/photo-turtlebot.json
Take it apart
Every spec becomes a kit of simple, 3D-printable parts (robotforge cad). This viewer lays the kit out the way the kit's own assembly file does, straight from the spec's numbers — flat views, or in 3D with the toggle. Click any part.
examples/photo-turtlebot.json…Reproduce it
Run these from a clone of the repository.
robotforge validate examples/photo-turtlebot.json
robotforge urdf examples/photo-turtlebot.json --out build/turtlebot3-waffle-pi.urdf
robotforge cad examples/photo-turtlebot.json
robotforge run-gate examples/photo-turtlebot.json
robotforge harness examples/photo-turtlebot.json